---
license: cc-by-nc-4.0
task_categories:
- robotics
tags:
- robotics
- robot-learning
- imitation-learning
- egocentric
- project-aria
- manipulation
- humanego
pretty_name: HumanEgo
size_categories:
- n<1K
---
# HumanEgo
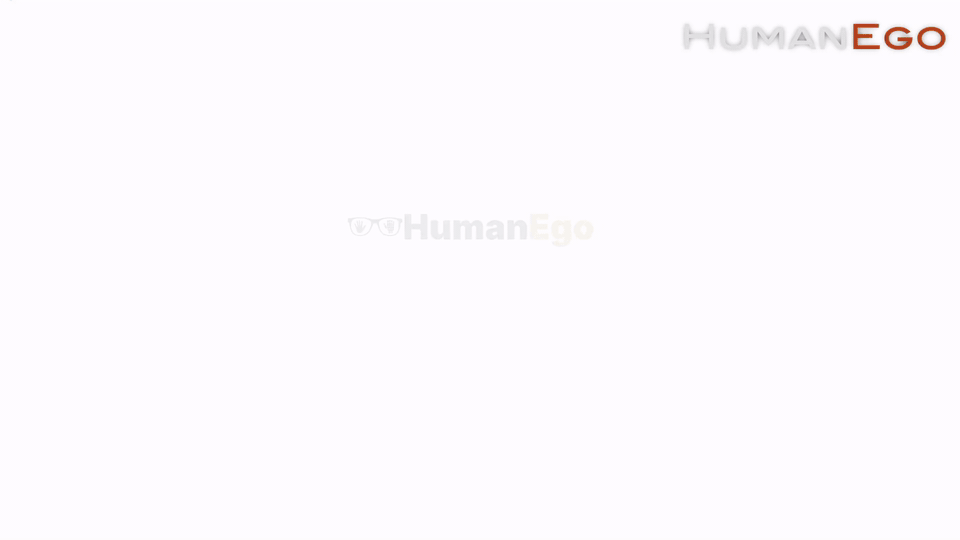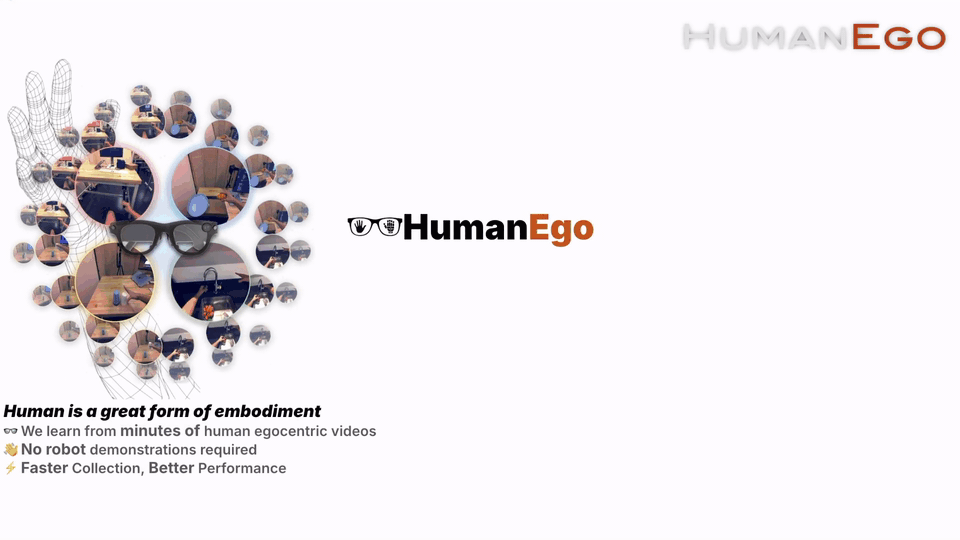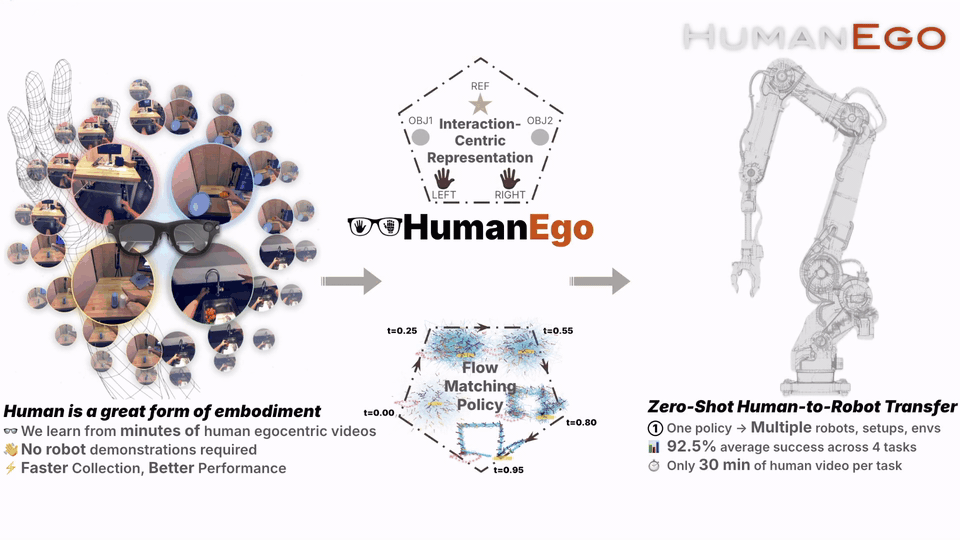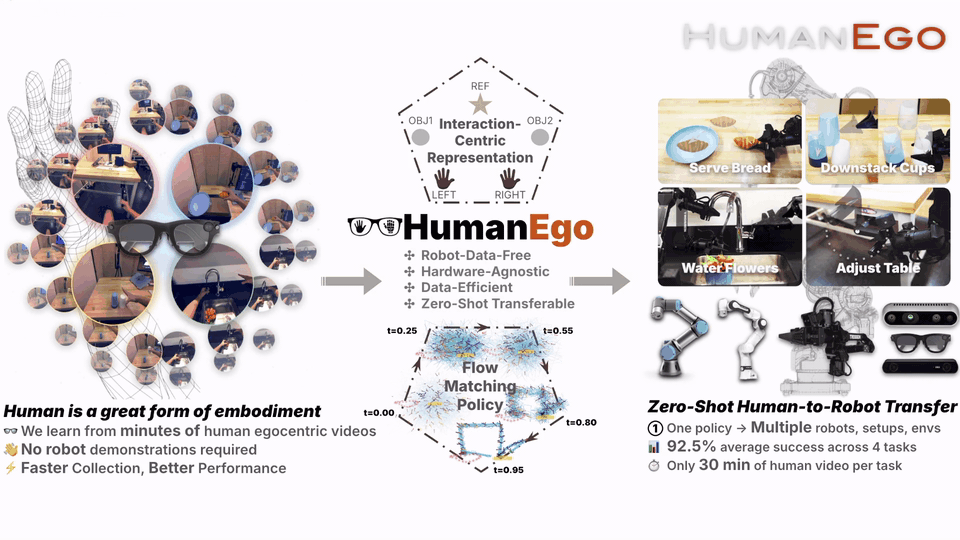
HumanEgo: Zero-Shot Robot Learning from Minutes of Human Egocentric Videos
🌐 Website ·
📄 Paper ·
💻 Code ·
🎥 Visualization Gallery
## Dataset Summary
**HumanEgo** is a dataset of **human egocentric manipulation videos** recorded with
**Project Aria** (Gen 1) glasses, paired with Meta **MPS** annotations (SLAM trajectories +
hand tracking) and the **full HumanEgo preprocessing output** — per-frame RGB, object/arm
segmentation, 3D hand & object tracking, and ready-to-train per-frame targets. It supports
learning manipulation policies from only minutes of human video (see the paper).
Each recording is a short (~30 s), single-task manipulation clip. The dataset ships both the
**raw inputs** (reproduce everything yourself) and the **precomputed outputs** (skip the GPU
pipeline).
## At a Glance
| | |
|---|---|
| **Tasks** | 2 — `serve_bread`, `water_flowers` |
| **Recordings** | 122 (61 + 61) |
| **Total size** | ~238 GB |
| **Sensor** | Project Aria Gen 1 — RGB (30 fps, 2 MP), SLAM (VGA), IMU / Baro / Mag / GPS |
| **Annotations** | MPS closed/open-loop trajectory, semidense points, online calibration, hand tracking |
| **Preprocessing** | object/arm masks, CoTracker tracks, 3D triangulation, arm-inpainted RGB, per-frame `training_data.json` |
🎥 Browse a visualization of every recording in the
[**HumanEgo Data Gallery**](https://huggingface.co/spaces/Leo-TX/humanego-gallery).
## Dataset Structure
```
/aria/mps___vrs/
├── sample.vrs # raw Aria recording (RGB / SLAM / IMU / ...) [INPUT]
├── slam/ # MPS SLAM: closed/open-loop trajectory, semidense [INPUT]
│ # points, online calibration, summary
├── hand_tracking/ # MPS hand tracking (hand_tracking_results.csv) [INPUT]
├── else/ # VRS metadata + health checks [INPUT]
└── preprocess/ # HumanEgo preprocessing output [OUTPUT]
├── aria_*_analysis.png # phase / SLAM / hand diagnostic plots
├── *_results.json # cotracker / camtriangulator / kptsselector results
├── dinosam_mask_obj*.png # object segmentation previews
├── object_centric.ply/png # final object-centric 3D scene
├── vis/ # visualization clips (aria_vis.mp4, visualkpts_vis.mp4, ...)
└── all_data.tar # per-frame data, packed (one tar instead of ~14k files)
```
`all_data.tar` unpacks to `all_data//`, with per frame:
| File | Meaning |
|---|---|
| `rgb.png` | extracted RGB frame |
| `rgb_WoArm.png` | RGB with the arm inpainted out (LaMa) |
| `rgb_*WArmObjKpts.png` | RGB with arm + object keypoints overlaid |
| `mask_obj1/2.png`, `mask_arm.png`, `mask_arm_and_obj.png` | segmentation masks |
| `aria_cam_rgb.json` | per-frame camera pose (`c2w`) + intrinsics |
| `aria_hands.json` · `aria_slam.json` · `aria_phases.json` | per-frame hand / SLAM pose / phase label |
| `training_data.json` | **per-frame training target** (schema below) |
### `training_data.json`
```jsonc
{
"metadata": { "idx", "ts", "w", "h", "fps",
"k": [3x3 intrinsics], "c2w": [4x4 cam->world], "anchor_key": "obj1" },
"obs": { "rgb_path", "mask_arm_path", "mask_obj_path",
"rgb_WoArm_path", "rgb_WArmObjKpts_path", ... },
"entities": {
"hands": { "right": { "T_hand_to_world": [4x4 SE(3)], "grasp": } },
"objects": { "obj1": { "T_obj_to_world": [4x4], "is_dynamic": }, "obj2": { ... } }
}
}
```
> The hamer / wilor / mediapipe hand-tracking outputs are ablation-only and are **not**
> included in this release.
## How to Download
No token or login required — the dataset is public.
```python
from huggingface_hub import snapshot_download
# one recording, input only (~0.6 GB) — enough to run preprocessing yourself
snapshot_download("Leo-TX/HumanEgo", repo_type="dataset", local_dir="./data",
allow_patterns=["serve_bread/aria/mps_serve_bread_000_vrs/*"],
ignore_patterns=["**/preprocess/*"])
```
Or use the helper from the [code repo](https://github.com/TX-Leo/HumanEgo) (pick task / count):
```bash
pip install huggingface_hub
python scripts/download_data.py --task serve_bread --num 20 # first 20, with precomputed output
python scripts/download_data.py --task all --num all # the whole dataset
python scripts/download_data.py --task serve_bread --input-only # inputs only, run the pipeline yourself
```
After downloading, unpack the per-frame archive:
```bash
tar -xf /preprocess/all_data.tar -C /preprocess
```
## Reproducing the Preprocessing
```bash
python -m preprocess.Preprocess \
--mps_path ./data/serve_bread/aria/mps_serve_bread_000_vrs --task serve_bread
```
See [`preprocess/README.md`](https://github.com/TX-Leo/HumanEgo/blob/main/preprocess/README.md)
for the full pipeline architecture and a description of every output file, and
[`datacollection/README.md`](https://github.com/TX-Leo/HumanEgo/blob/main/datacollection/README.md)
to record and MPS-process your own Aria data.
## Dataset Creation
Recordings were captured with Project Aria Gen 1 glasses and processed with Meta's Machine
Perception Services (MPS) for SLAM and hand tracking. The HumanEgo preprocessing pipeline then
segments each clip into **Navigation / Transition / Manipulation** phases, isolates the
object-centric window, and produces object/arm segmentation (Grounding DINO + SAM 2), 2D
keypoint tracking (CoTracker3), 3D triangulation, arm inpainting (LaMa), and the consolidated
per-frame `training_data.json`.
## Considerations & Limitations
- Egocentric recordings may contain incidental views of people and environments — use
responsibly and in line with Project Aria's terms of use.
- This is a compact, task-focused dataset (2 tasks) designed for few-minutes / zero-shot
learning, not a large-scale pretraining corpus.
## Citation
```bibtex
@misc{humanego2026,
title = {HumanEgo: Zero-Shot Robot Learning from Minutes of Human Egocentric Videos},
author = {Wang, Zhi and He, Botao and Yu, Kelin and Lee, Seungjae and Gao, Ruohan and Huang, Furong and Aloimonos, Yiannis},
year = {2026},
eprint = {2605.24934},
archivePrefix = {arXiv},
primaryClass = {cs.RO}
}
```
## License
Released under [CC BY-NC 4.0](https://creativecommons.org/licenses/by-nc/4.0/) — free for
**noncommercial** use; commercial use requires a separate license (see the
[code repo](https://github.com/TX-Leo/HumanEgo)). Built on
[Project Aria](https://www.projectaria.com/) (Gen 1 glasses & MPS) — please also respect their
terms of use.
## Acknowledgements
This dataset and its preprocessing pipeline build on
[Project Aria](https://www.projectaria.com/) /
[MPS](https://facebookresearch.github.io/projectaria_tools/docs/intro),
[CoTracker3](https://github.com/facebookresearch/co-tracker),
[Grounding DINO](https://github.com/IDEA-Research/GroundingDINO),
[SAM 2](https://github.com/facebookresearch/sam2),
[LaMa](https://github.com/advimman/lama),
and [Orient-Anything](https://github.com/SpatialVision/Orient-Anything).